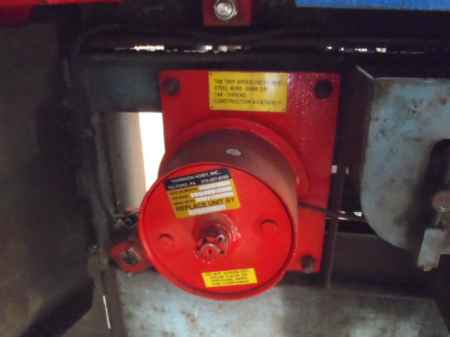
But I doubt the motor encounter is causing UIM faults, they would be more like 681s or something similar. Pos. encoder or traction is where I would focus. Shielding is important on the Pos enc too, make sure there are no ground loops i.e. shield grounded on one end and one end only. If you have the optical gov setup that JC mentioned the board should be as high as it can be without rubbing the plastic ring, centered on the plastic ring, the ring needs to be kept clean and make sure the black part isn't scratched off anywhere or it should be replaced, oh and make sure there isn't too much slop on the gov rope at the car attachment.
"Synergy" is the MRL product, it uses a Torin PM gearless machine and either an Accord drive or a 10K with the RC2 adapter like your picture. On the Synergy, in addition to the encoder shielding, the brake switch shield should be landed on one end too but the brake coil and motor wiring shield needs to be grounded on both ends to keep the noise in. Also, just because the wires land to the shield terminals doesn't mean they're grounded.
I'll send you something on setting up the logfile.